Loading...
Loading...
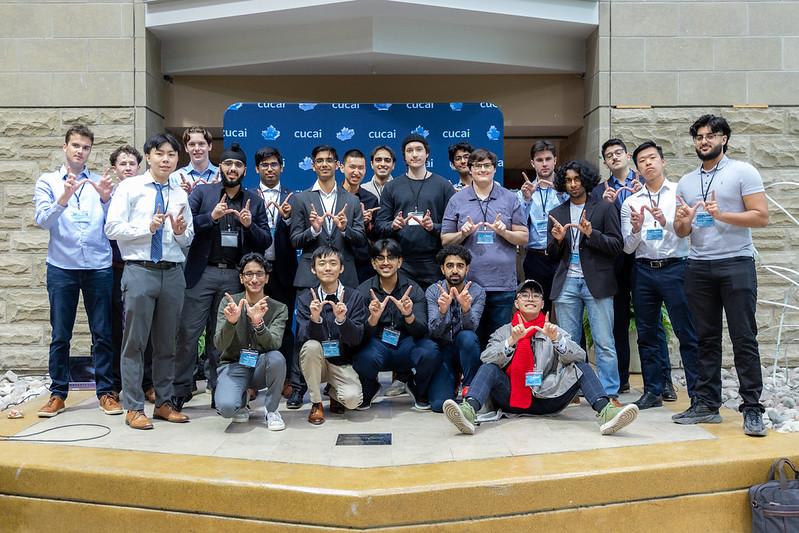
A skilled and engaged team of 4-6 students looking to disrupt current industries and practices through artificial intelligence, machine learning, and other disruptive technologies.
Below you can see the projects we’ve been working on, and click on any one to learn more.
Develop real-time computer vision for obstacle avoidance on a flying quadcopter.
In collaboration with ARA Robotics, the project will use a camera and onboard Jetson computing to help a quadcopter perceive and navigate its surroundings without lidar.
Build a proof-of-concept federated learning package on DCP so hospitals can train a shared machine-learning model without sharing private data.
The initial application is predicting treatment response to biologics for psoriatic arthritis. The package will be publicly released as open source, and the project offers hands-on experience researching ML models and implementing federated learning techniques.
Develop a responsible AI evaluation system that assesses AI-generated outputs and actions before they enter real-world workflows.
The team will evaluate reliability, fairness, safety, and the need for human review while working with industry partners to shape the system around a real responsible-AI challenge.
Contribute to an open-source terminal agent for AI-assisted software development.
The project offers hands-on experience with agent orchestration, MCP and skills integrations, permissions, checkpoints, testing, CI, and browser automation in a public TypeScript and Bun codebase.
Explore whether large language models can improve dynamic cloud resource management through context-aware autoscaling decisions.
The research will evaluate when LLM-based reasoning adds value against traditional threshold and control-policy methods, including trade-offs in performance, resource efficiency, and adaptability.
Study how AI-generated recruiter profiles and deepfakes influence trust and security decisions during multi-step remote job scams.
In collaboration with Menlo Park Intelligence, the project will use a two-stage recruitment experiment to measure compliance, hesitation, and the effects of visual fidelity on later scrutiny.
Investigate whether a small diffusion renderer can compose unseen visual attribute combinations in interactive game scenes.
The project will test how dataset design, model capacity, and architecture affect controllable generative game rendering under realistic research constraints.
Build an interpretability toolkit to investigate the internal circuits behind uncertainty, branching, premise commitment, and error recovery in reasoning models.
The team will use sparse autoencoders and causal interventions on models such as Qwen-2.5-Math and DeepSeek-R1-Distill to develop open-source tools and a diagnostic benchmark for AI safety research.
Develop a high-precision drone, sensor, and satellite-validation system for early wildfire detection.
The team will combine thermal imaging, gas sensing, onboard computing, MATLAB analysis, and satellite data to improve wildfire monitoring and prevention.
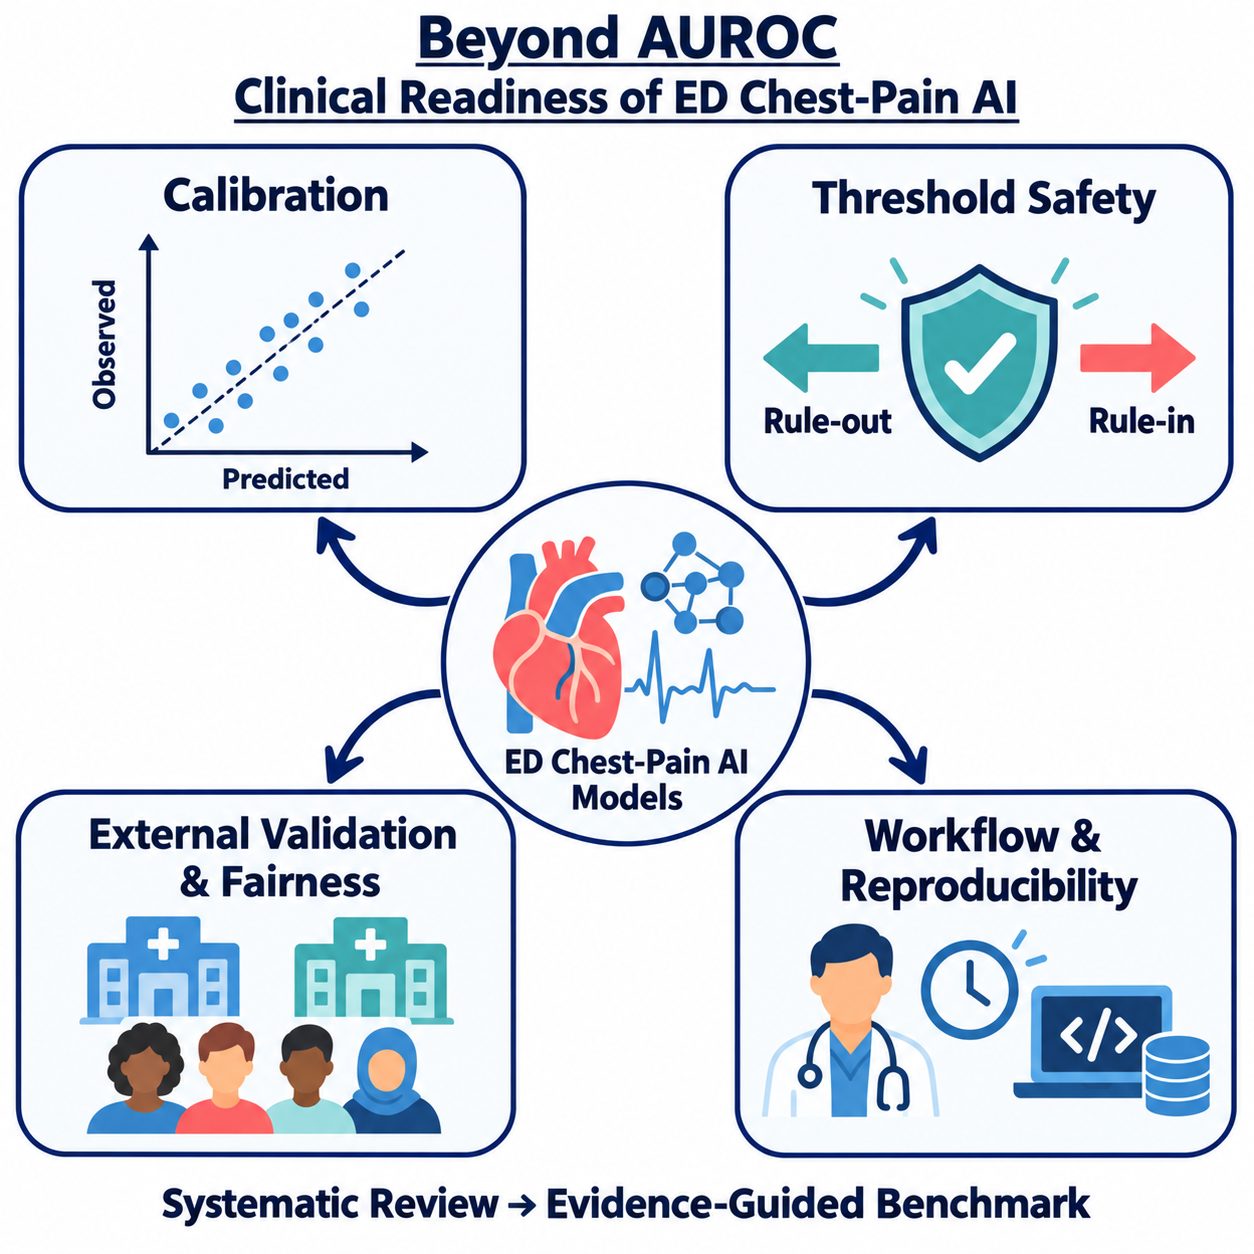
Evaluate what evidence is needed before chest-pain AI models can be trusted in real emergency-department decisions.
Beyond AUROC will assess calibration, safety of decision thresholds, generalizability, and workflow fit before shaping a feasible MIMIC-IV benchmark, subject to access and linkage feasibility.
Build a governed AI platform that enables intelligent agents to support complex business work and informed decision-making.
Working with Electric Mind, the team will create a reliable, traceable, and secure foundation for agents that analyze business problems and coordinate information across an organization.
Investigate how distinct team roles influence neural synchronization during collaborative problem-solving.
The project combines experimental neuroscience and EEG machine learning to study neural coordination in realistic teamwork settings.
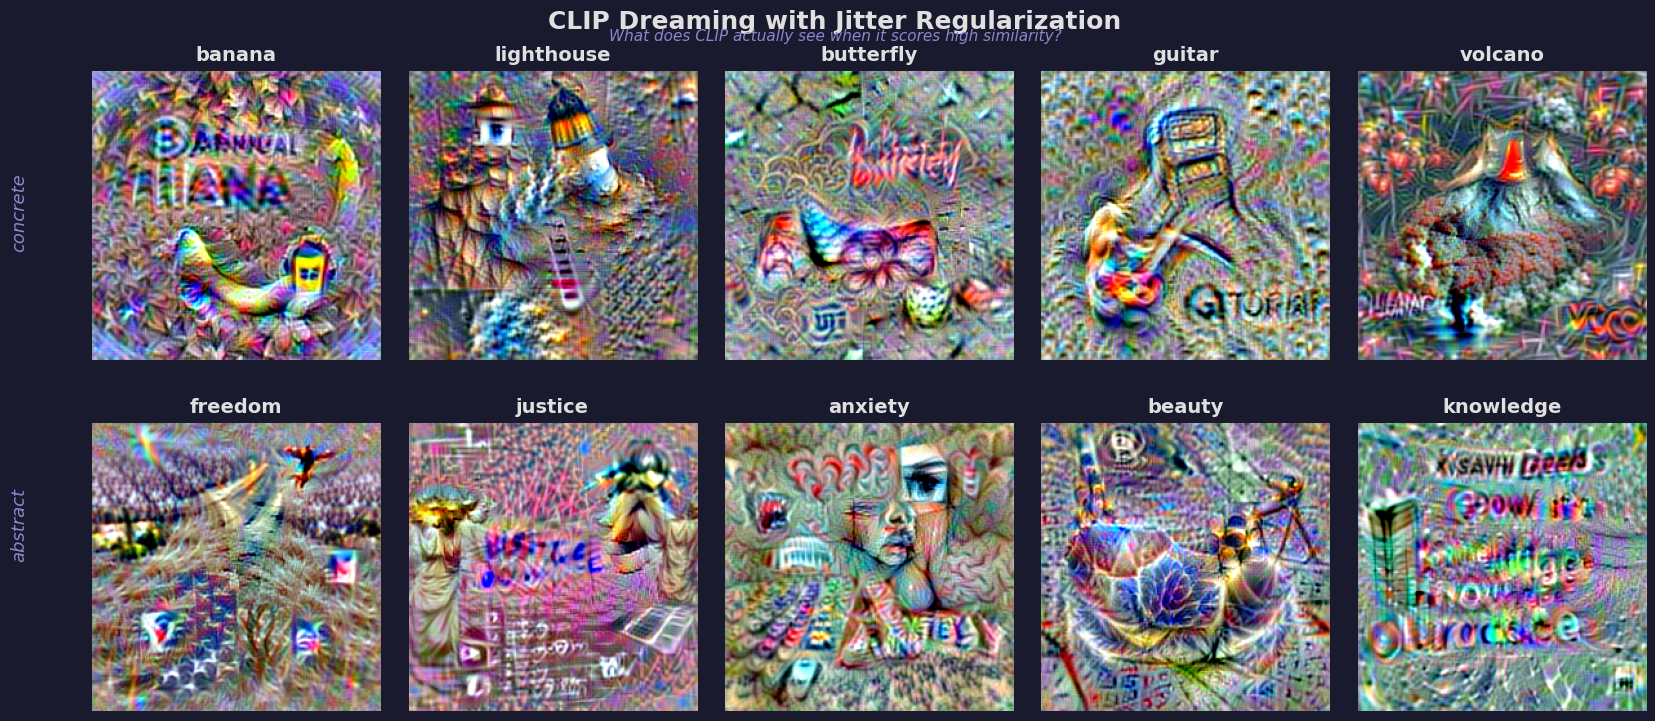
Study when CLIP similarity scores correspond to genuinely grounded visual concepts rather than abstract numerical matches.
The project will compare pixel, Fourier, and differentiable-vector substrates to identify when coherent images emerge from CLIP-guided optimization.
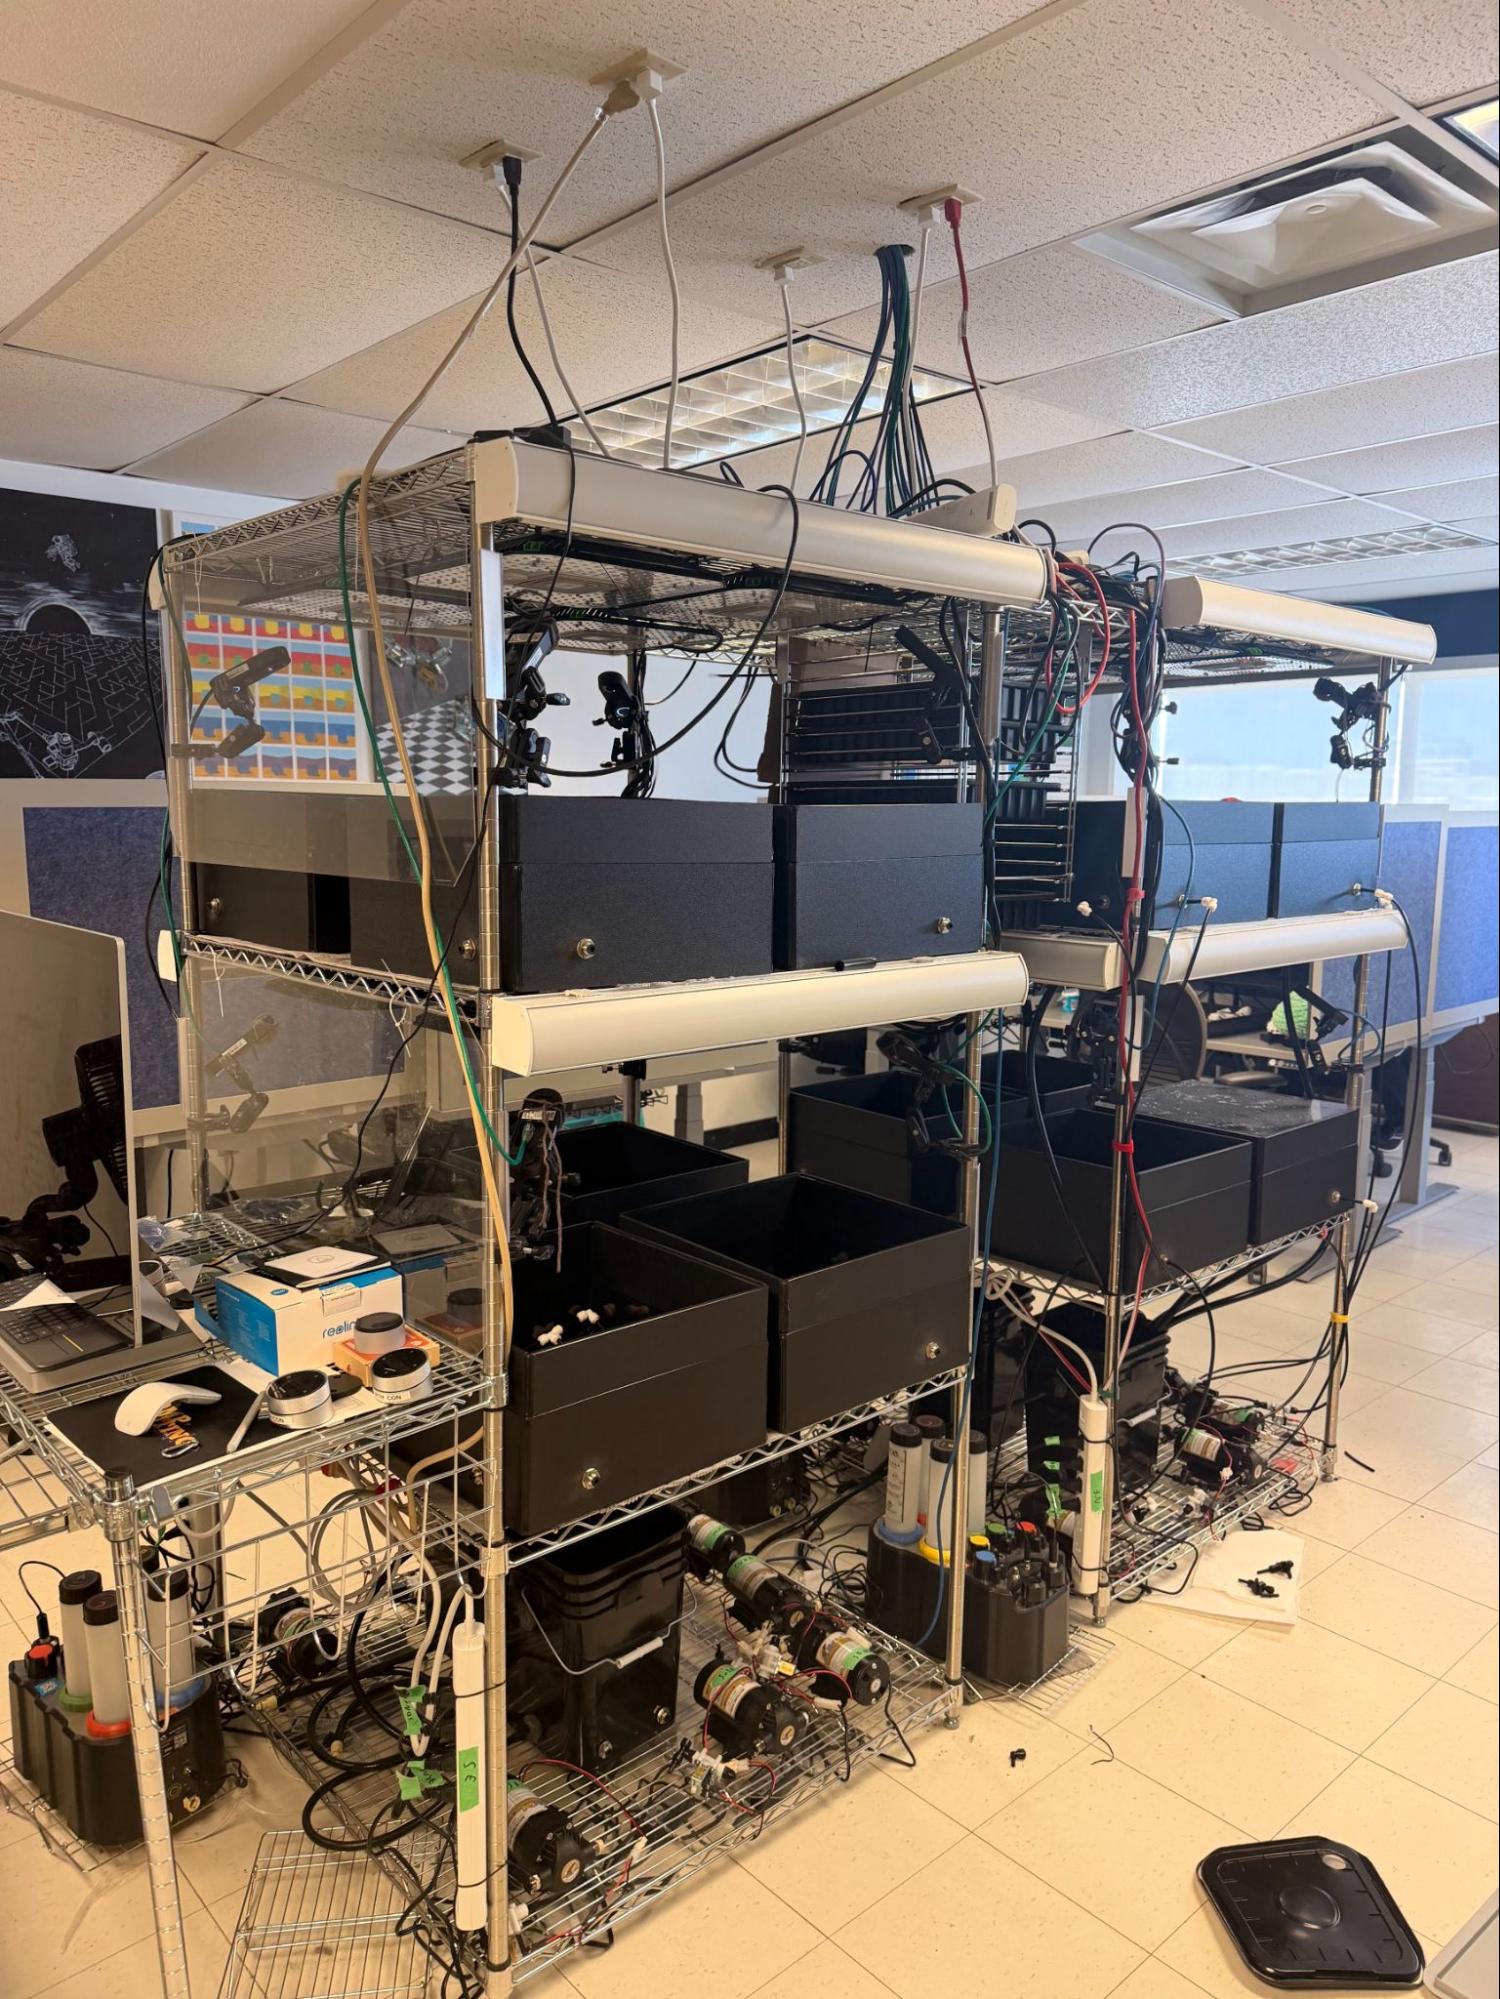
Use computer vision to measure plant growth in indoor farms and help automate growth-optimization decisions.
CanopyMap addresses the lack of high-quality training data for indoor agriculture by applying existing segmentation models to camera data from an aeroponic farm.
Compare retrieval-augmented generation systems on questions that require reasoning across a patient's medical timeline.
The project will evaluate when vector, metadata-based, GraphRAG, and temporal GraphRAG systems retrieve and use evidence correctly while avoiding privacy risks with synthetic patient data.
Build machine learning models that answer practical questions about how vehicles and telematics devices are moving.
Use real vehicle sensor and engine data to infer reversing, installation quality, and device orientation in messy real-world conditions.
Explore a conversational AI framework that explains complex Advanced Process Control behaviour to engineers and operators in mineral processing.
The framework will combine process data, controller information, and operational knowledge to produce clear, evidence-based explanations that support better operational decisions.
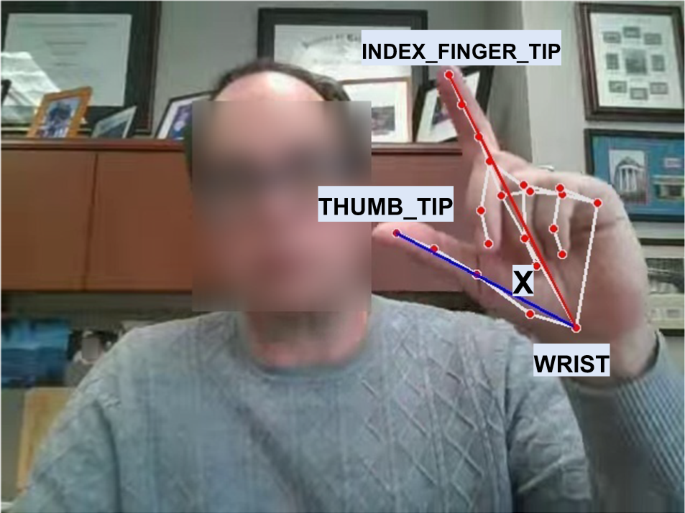
Use monocular video and uncertainty-aware deep learning to estimate Parkinsonian motor symptom severity while communicating when the model is unsure.
The project combines pose estimation, temporal modelling, explainability, fairness, and human oversight to explore more transparent and responsible clinical decision support.